KAIST's BeetleBot Moves at the Bend of a Finger
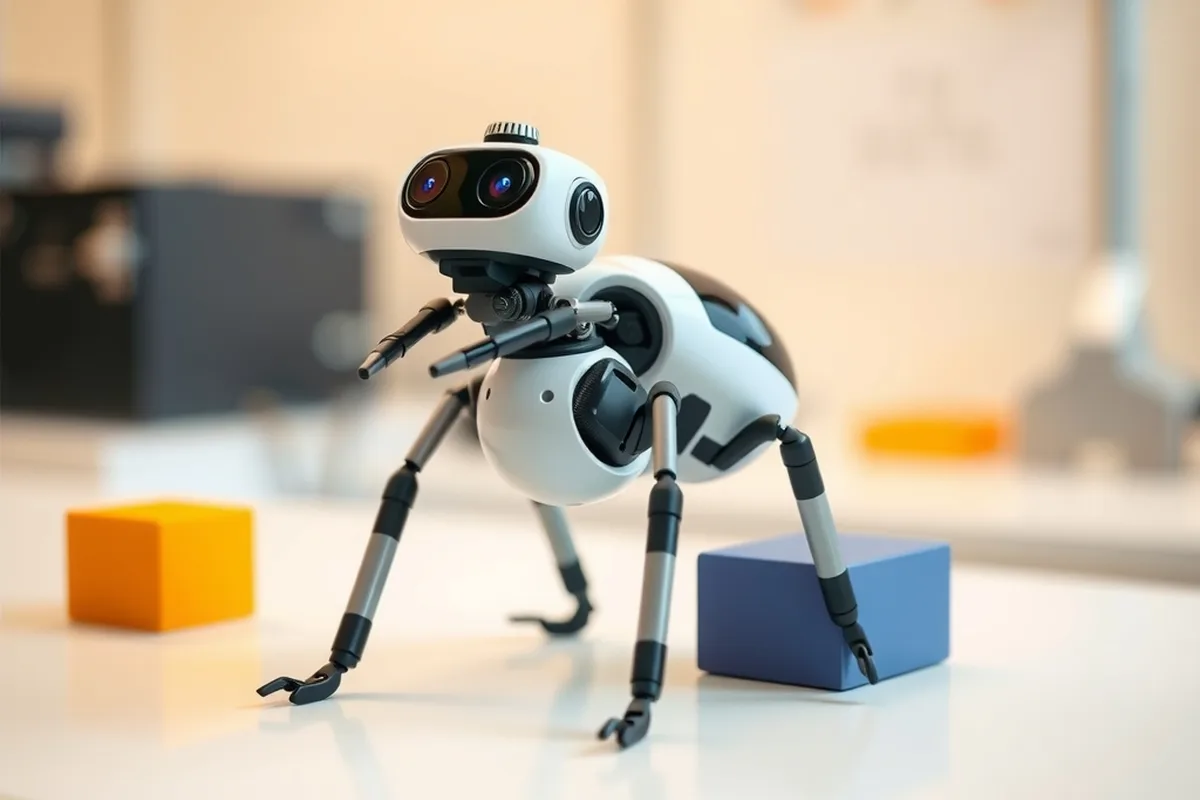
Imagine steering a tiny robot just by bending your finger. Researchers in South Korea have made that possible. On 13 October, KAIST announced BeetleBot, a small soft robot modelled on a beetle. It was developed by a team led by Professor Sang Ouk Kim, working with research groups at Caltech and NTU.
Soft robots are made from flexible materials, but it is hard to fit movement, sensing and control into one small body. To solve this, the team first studied how a beetle's leg muscles move its joints. They used what they learned to decide where to place the robot's artificial muscles and how to design its legs.
The muscles are made from a liquid crystal elastomer, a material that contracts when heated. Each muscle can work on its own, so the robot can walk forward and turn left or right. A soft gripper, inspired by a beetle's mandibles, closes around objects, while a pressure sensor detects when it is touching something.
The user wears a stretchy sensor patch on one finger. Bending and straightening the finger creates four commands: move forward, turn left, turn right and grip. These travel to the robot over Bluetooth Low Energy. In return, a small onboard camera and the gripper's sensor send images and touch data back to the user. This two-way feedback helps the user plan the next move.
In tests, BeetleBot avoided obstacles, approached a target, then gripped and carried it. The work was published in Science Advances on 19 August.
The team hopes robots like this could one day inspect narrow spaces and retrieve small objects where people cannot easily reach. First, the muscles need to become faster and more energy efficient, and the robot must be tested in real working environments.